Robotics · 5 min read
How humanoid robots are learning to move
Balance stopped being programmed and started being learned.
From equations to experience
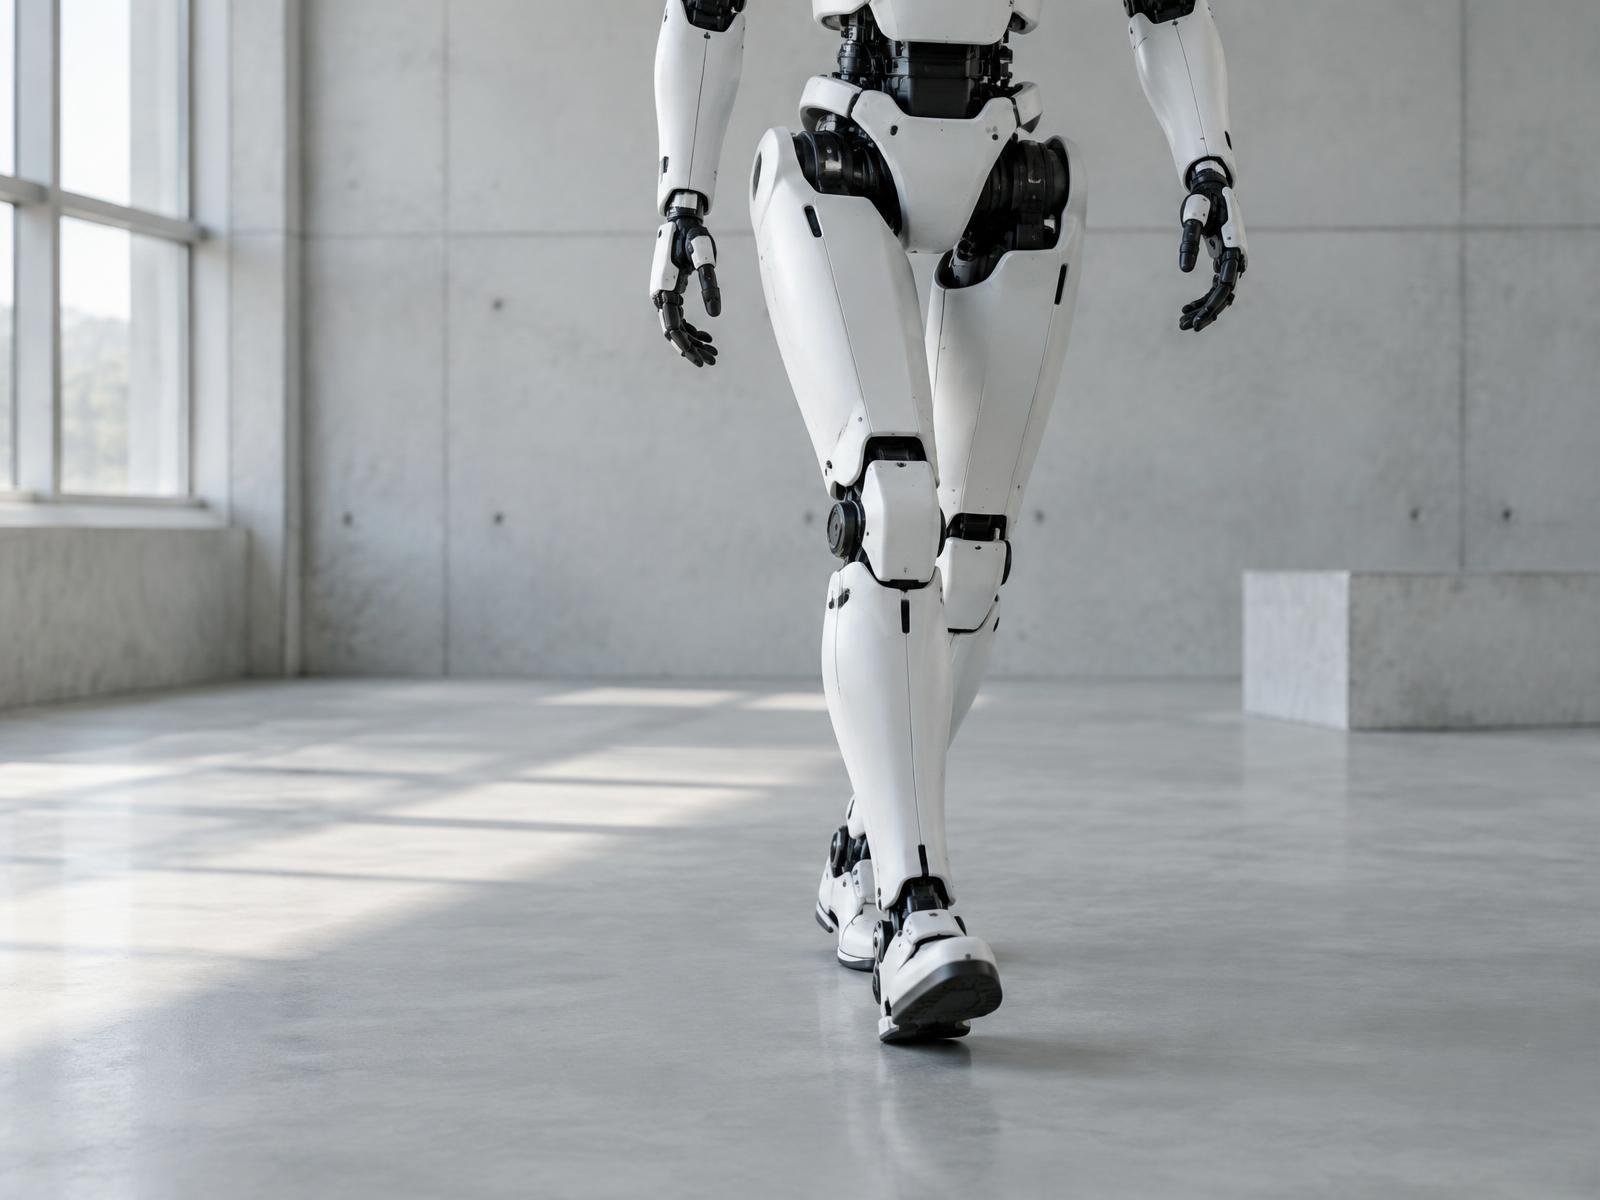
For decades walking robots followed hand-written models of their own dynamics. Today most impressive demonstrations come from policies trained in simulation across millions of falls, then transferred to hardware.
millions
Simulated falls behind a single stable gait
Why the transfer works at all
Randomising friction, mass and latency during training forces the policy to be robust rather than precise. A controller that survives a thousand imaginary floors tends to survive a real one.
The machines are not being taught to walk. They are being allowed to fail until walking is what remains.
What remains hard
Hands. Manipulation demands force control and contact reasoning that locomotion largely avoids, and it is where most humanoid programmes now spend their time.